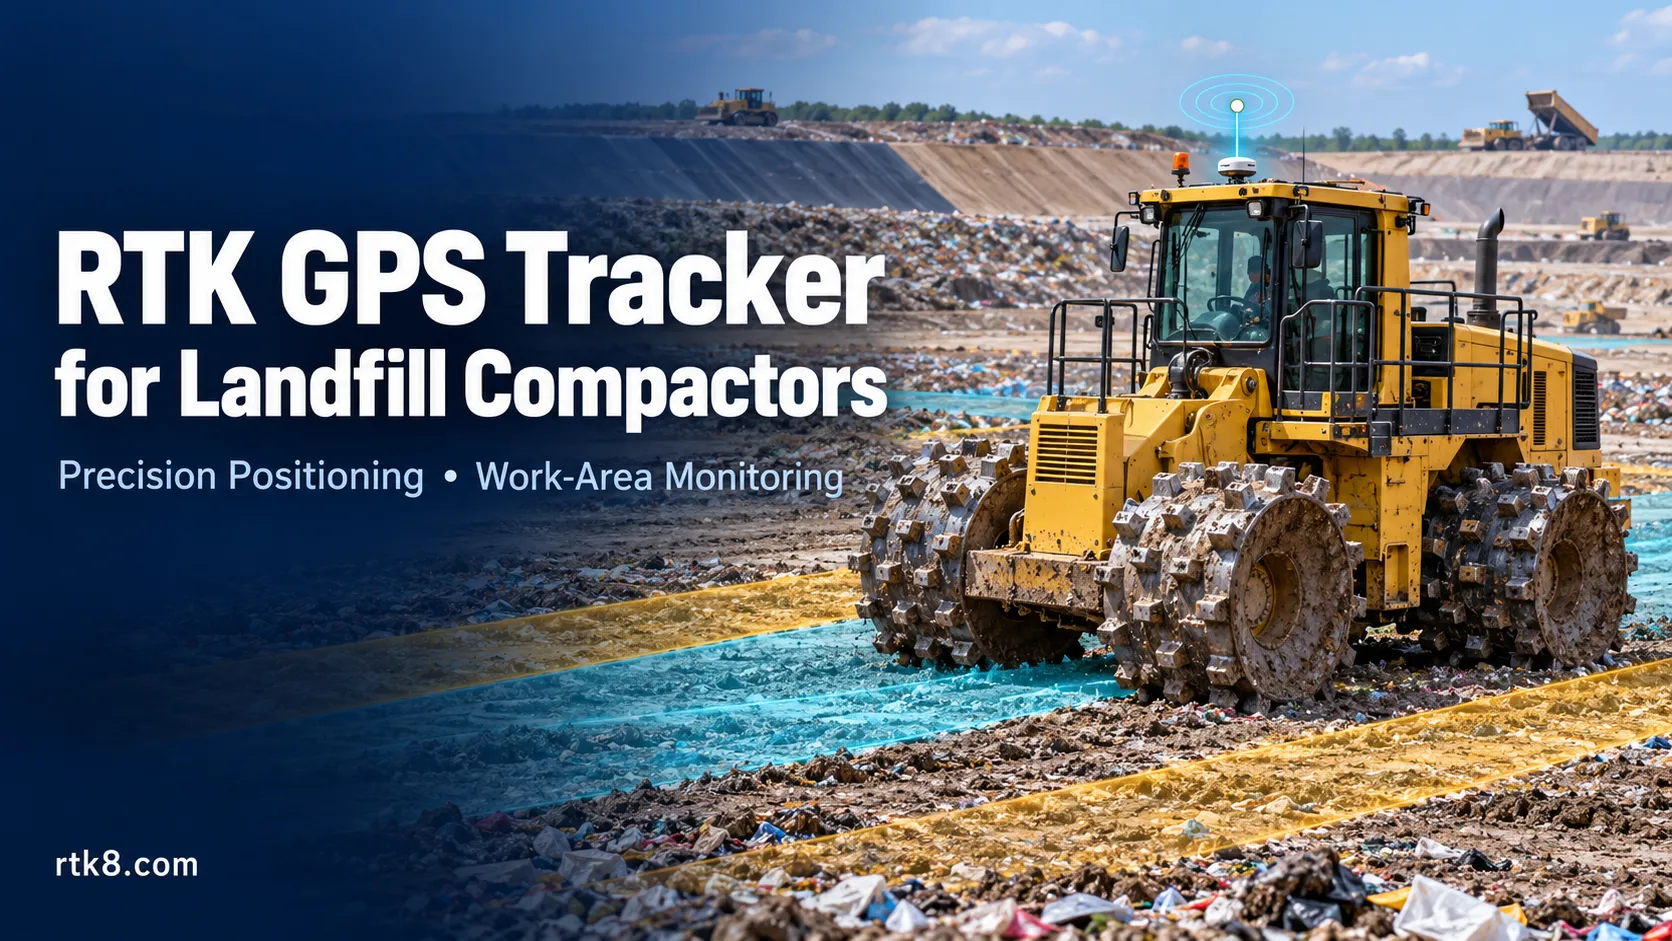
RTK GPS Tracker for Landfill Compactors: An OEM Solution for Work-Area Monitoring
A landfill compactor can operate for hours within a relatively small area. A basic vehicle tracking system may show that the machine stayed inside the landfill, but supervisors often need more detail: which working zones it visited, how its paths overlapped and where recorded coverage remains incomplete.
An RTK GPS tracker for landfill compactors provides positioning data that can support these questions. Combined with suitable machine geometry, operating-state information and application software, it can form the basis of a more detailed work-area monitoring system.
The project should begin with a clear distinction between vehicle location, estimated coverage and measured compaction quality.
Why Use RTK Positioning on a Landfill Compactor?
Conventional vehicle tracking is useful for fleet location and journey history. Within a compact working area, however, position uncertainty can make neighboring paths difficult to distinguish.
RTK uses GNSS measurements and compatible correction data to support centimeter-level positioning under suitable conditions. Actual field performance depends on the receiver, antenna installation, correction service and operating environment.
For a landfill project, the objective is to obtain sufficiently reliable position records to support the required spatial analysis.
Possible applications include:
- Reviewing machine routes within assigned working areas.
- Estimating coverage from the machine’s effective working width.
- Comparing activity between shifts.
- Identifying areas requiring operational review.
- Connecting location records with supported machine-status data.
These outputs require application logic beyond receiving coordinates.
What Should the Vehicle Terminal Provide?
A proposed OEM configuration combines an RTK-capable GNSS receiver, a suitable antenna, vehicle power conditioning, communication hardware and firmware that preserves positioning quality information.
The terminal specification should define the following capabilities.
| Component or function | Project requirement |
|---|---|
| RTK GNSS receiver | Compatibility with the intended correction source |
| GNSS antenna | Secure installation with suitable satellite visibility |
| Correction-data connection | Delivery of the messages required by the receiver |
| Vehicle power input | Compatibility with the machine’s electrical supply |
| Position records | Coordinates, timestamps and solution status |
| Local storage | Defined recording behavior during upload interruptions |
| Data interface | Documented protocol or API integration path |
| Optional machine inputs | Validated signals for the required operating states |
Hardware interfaces and supported data fields should be agreed for the selected terminal rather than assumed from a general product description.
Separate Correction Delivery from Platform Upload
An RTK tracking system has two communication tasks.
The receiver needs correction data to support its RTK solution. The business platform needs vehicle records for monitoring and reporting.
NTRIP is one method of delivering GNSS correction data over an internet connection. Depending on the deployment, a compatible local base-station link may be another option.
Specify how the system behaves when either connection fails.
If platform connectivity is interrupted, a terminal with suitable storage may continue recording locally. If correction delivery is interrupted, the receiver’s positioning state and accuracy may change.
Recovered route records should retain their original timestamps and quality fields. Uploading a record later does not improve the positioning quality it had when it was collected.
Turn Vehicle Positions into Estimated Coverage
A sequence of antenna positions is a route, not a complete coverage map.
To estimate the area traversed by the compactor, the application needs a defined relationship between the antenna and the machine’s working footprint.
Relevant inputs may include:
- Effective working width.
- Antenna mounting position.
- Offset from the antenna to the working footprint.
- Vehicle orientation.
- Forward and reverse operation.
- Articulation or steering geometry, where relevant.
- Position sampling interval.
The software can then estimate the area swept by the working footprint between accepted position records.
At low speed or while stationary, direction derived from successive positions may be unreliable. Projects requiring precise footprint orientation should evaluate an appropriate heading or attitude solution.
Validate the resulting coverage map against controlled machine movements before using it for operational decisions.
Define What Counts as a Pass
A platform should not count every position sample as another compaction pass.
A slow-moving machine produces many records in one location. A stationary machine may also produce slightly changing coordinates. Neither situation automatically represents repeated productive passes.
The project therefore needs an explicit pass-counting rule.
For example, the software may identify a new traversal only after the working footprint leaves and subsequently re-enters a defined map cell. Turning, reversing and boundary movement need their own handling.
Cell size should reflect the validated positioning performance and the operational purpose. Extremely small cells can make a map look precise while exaggerating noise and geometry errors.
Keep the counting method documented so that reports remain comparable between machines and software versions.
Coverage Does Not Establish Compaction Quality
An RTK route can show where the machine was recorded. A coverage model can estimate where its working footprint traveled.
Neither result alone establishes material density or confirms that a compaction target has been achieved.
Compaction assessment may require additional machine measurements, material information, layer details and independent testing appropriate to the operation.
Use clear report labels such as:
- Estimated covered area.
- Recorded traversals.
- Time within the assigned work zone.
- Position-quality availability.
- Areas with insufficient valid records.
Reserve terms such as “verified compaction quality” for results supported by an appropriate measurement and validation method.
Preserve RTK Status in Every Relevant Record
A map should make changes in positioning quality visible.
Receiver documentation commonly distinguishes RTK fixed and RTK float states. Receiving correction data does not mean the receiver remains in a fixed solution continuously.
Where supported, retain:
- Position timestamp.
- RTK solution state.
- Estimated position uncertainty.
- Correction age.
- Satellite information.
- Device and communication status.
Define which records qualify for detailed coverage analysis. Records that fail the quality criteria can remain available for diagnostics while being marked separately in operational reports.
An RTK fixed status is useful evidence, but field checks are still needed to validate the complete installation and coordinate alignment.
Build Reports Around the Working Shift
A useful report links machine records with the correct work area and time period.
Suggested fields include:
| Report field | Operational purpose |
|---|---|
| Machine and shift | Identify the reporting scope |
| Assigned work-area version | Preserve the boundary used for analysis |
| Valid recorded operating time | Show the period supported by usable records |
| Estimated coverage | Review the modeled working footprint |
| Traversal distribution | Compare repeated coverage under the defined rules |
| Position-quality gaps | Identify areas where analysis is incomplete |
| Correction interruptions | Explain changes in RTK availability |
Keep historical work-area versions. Editing a boundary today should not silently change the meaning of a report produced for an earlier shift.
Validate the Solution on the Actual Machine
Begin with controlled movements in a representative area.
Test straight runs, overlapping paths, turns, reversing and stationary periods. Include the normal machine configuration and final antenna mounting position.
Compare the recorded path with independently established reference points or routes. Then check whether the software applies the working width and offsets correctly.
The pilot should also examine correction interruptions, communication recovery, device restarts and vibration during normal operation.
Agree acceptance criteria before testing. Relevant measures include position error, usable-data availability, recovery time and coverage-model consistency.
OEM RTK Tracking Development with Jinshengchang
Shenzhen Jinshengchang Technology Co., Ltd. can discuss RTK vehicle-terminal customization and platform integration for industrial tracking projects.
For a landfill compactor application, define the project as a combination of positioning hardware, installation geometry and purpose-built reporting software.
Provide the machine model, electrical supply, deployment country, correction-service arrangement, working width, antenna location and required reporting outputs.
Optional integrations, such as machine operating states, fuel information or additional sensors, should be assessed against the available interfaces.
A successful RTK GPS tracker for landfill compactors provides traceable position records and a clearly defined analysis method, allowing supervisors to understand what the data supports and where further verification is needed.
Frequently Asked Questions
Can an RTK tracker measure compaction density?
RTK positioning alone does not measure density. It can support route and coverage analysis; compaction assessment requires suitable additional evidence.
Does the system need a local RTK base station?
Not necessarily. A compatible network correction service may be suitable. The choice depends on service availability, connectivity and the required performance.
Will every recorded position have centimeter-level accuracy?
No. Performance varies with reception conditions, correction availability and receiver solution state. Retain quality information and validate accuracy in the actual installation.
Can the system produce coverage and pass-count reports automatically?
These reports can be specified as application-development requirements. They need machine geometry, quality filtering and a documented counting method in addition to the tracker’s position data.